
New research finds that autonomous vehicles can gain most of the benefits of adaptive route planning with only a few course corrections
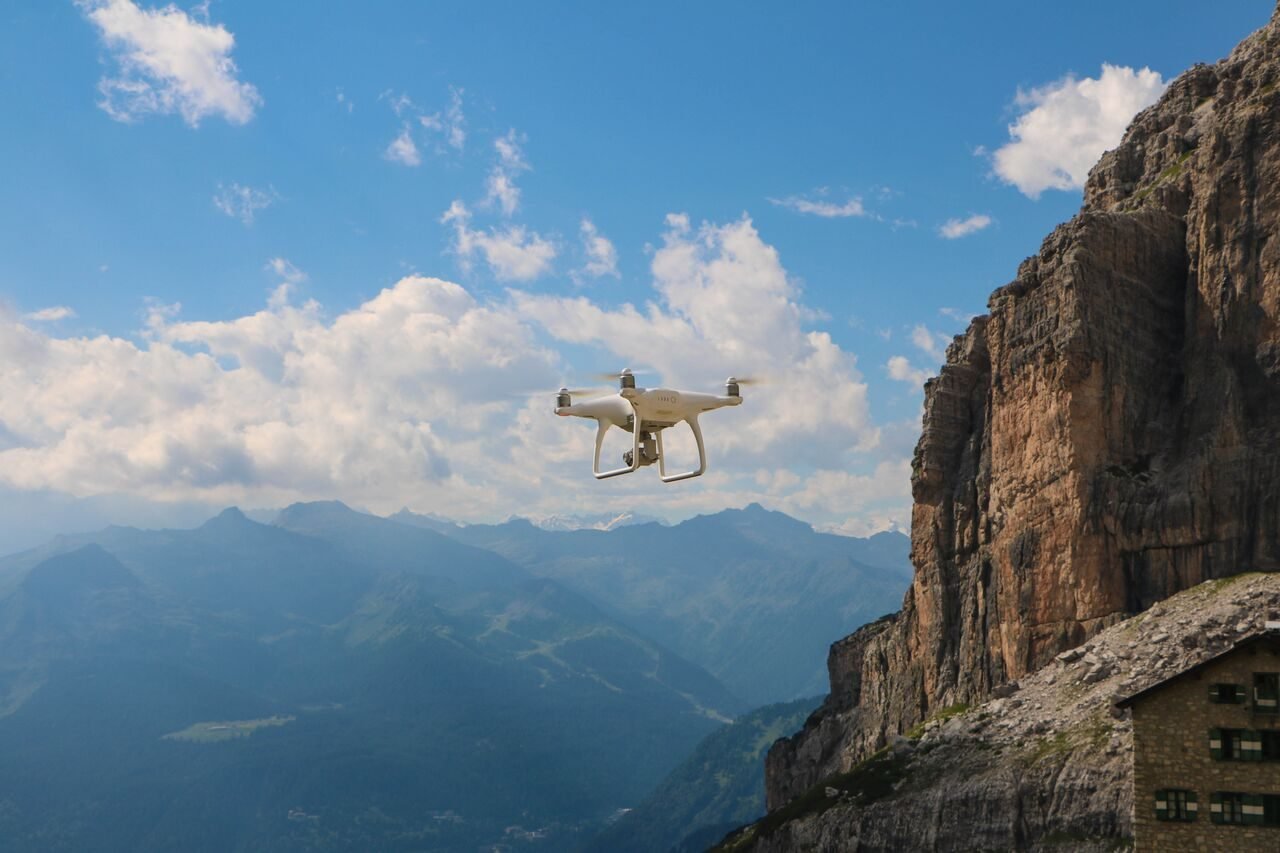
For an autonomous drone searching for a missing person, new information can change the mission. An image or sensor reading may suggest that the aircraft should search somewhere else.
But how often does the drone need to reconsider its route?
New research from The University of Texas at Austin suggests the answer may be surprisingly few times. Researchers found that an autonomous vehicle could gain most of the benefits of fully adaptive route planning by recalculating its path only two or three times.
The approach could make autonomous searches faster and less computationally demanding. Potential applications include search and rescue, infrastructure monitoring, scientific research and agriculture.
Finding a Middle Ground for Drone Autonomy
Rohan Ghuge, assistant professor of information, risk, and operations management at the McCombs School of Business at The University of Texas at Austin, led the research. He worked with Rayen Tan and Viswanath Nagarajan of the University of Michigan.
The researchers examined a common challenge in autonomous operations. A drone may start a mission with limited information. As it collects data, the best route can change.
“How much data do you need to get to say, ‘OK, now I need to stop. I need to change my mind. I need to change the path I’ve been going on.’” Ghuge said.
One option is a fully adaptive system. It continually changes its planned route as new information arrives. This can produce better routes, but repeated calculations require computing resources and time.
At the other extreme, a nonadaptive system follows its original route regardless of what it discovers.
The researchers developed a hybrid approach between those two models. The autonomous vehicle follows a planned route for a set period, called a “round.” It then uses the information collected during that round to calculate its next route.
Two or Three Adjustments May Be Enough
Computer simulations showed a significant difference in processing speed.
A hybrid solution using two adaptive rounds was 15 times faster than the fully adaptive model. Its cost was only 12% higher than that of a comparable fully adaptive search.
The researchers also found diminishing returns from additional adjustments. After three rounds, accuracy did not improve significantly.
“You don’t really need all the data to make good decisions,” Ghuge said. “If you’re doing the searches sequentially, two or three rounds are sufficient.”
The finding could be important for drone operations, where aircraft face limits on battery power, onboard computing resources and communications.
“Constantly replanning can itself be very expensive,” Ghuge said. “When you have a robot which changes its solution just a few times, you still get most of the benefit of being fully adaptive. It’s more practical, with a small added cost.”
Implications for Real-World Drone Operations
The principle could apply to missions where drones search large areas while gathering new information. Utilities, for example, could use autonomous systems to help locate the source of an outage.
The research does not mean that drones themselves can search an area 15 times faster. Rather, the researchers found that their two-round model solved the path-planning problem 15 times faster than the fully adaptive model in simulations.
The broader finding points to a practical issue as drone autonomy advances. More frequent decision-making does not necessarily produce proportionally better results. For some missions, a few well-timed course corrections may provide much of the value of continuous adaptation.
Read more:
Miriam McNabb is the Editor-in-Chief of DRONELIFE and CEO of JobForDrones, a professional drone services marketplace, and a fascinated observer of the emerging drone industry and the regulatory environment for drones. Miriam has penned over 3,000 articles focused on the commercial drone space and is an international speaker and recognized figure in the industry. Miriam has a degree from the University of Chicago and over 20 years of experience in high tech sales and marketing for new technologies.
For drone industry consulting or writing, Email Miriam.
TWITTER:@spaldingbarker
Subscribe to DroneLife here.
