
A De Montfort University Leicester (DMU) researcher will study whether 3D printing can produce artificial muscles for a new generation of soft robots. Dr Meisam Abdi is one of only eight engineers in the UK to receive a 2026/27 Royal Academy of Engineering/Leverhulme Trust Research Fellowship. The award will let him spend up to a year focused on materials and structures that could one day allow robots to move, sense and respond more like living organisms.
The fellowships support mid-career engineers by funding replacement academic staff, so Fellows can dedicate most of their time to research for up to a year. According to the Royal Academy of Engineering, this year’s eight fellowships cover a range of engineering challenges, including surgical robots, artificial vision, energy harvesting and AI, alongside Abdi’s work on soft robots capable of improved interaction with humans.
Printing structures that move, sense and generate power
During the fellowship, Abdi will design and test 3D printed structures made from smart materials, aiming to produce an artificial muscle that combines three functions in one: generating motion, sensing its surroundings, and harvesting small amounts of electricity from vibration or mechanical movement.
The work starts in simulation. Using computer-aided engineering, Abdi will evaluate combinations of piezoelectric, conductive and structural materials across different architectures. The most promising designs will then be printed and tested in the lab to measure how they respond to electrical stimulation.
The structures will not replicate human muscle tissue. Instead, Abdi will use additive manufacturing to create architected structures whose geometry defines how they behave. “By changing the materials and the geometry of these structures, we want to see whether we can create properties that don’t currently exist naturally,” he said.
Solving the piezoelectric problem
Piezoelectric materials sit at the core of the project. They generate electrical charge when deformed and change shape when exposed to an electrical field, which makes them candidates for both actuation and sensing.
The drawback is that the best-performing piezoelectric materials tend to be stiff and brittle, and several of the most common ones contain lead. Those traits clash with the requirements of a soft, flexible and more sustainable artificial muscle.
Abdi plans to address this by pairing tailored material compositions with purpose-designed 3D printed cellular structures. The goal is to reach the necessary performance while keeping the final structure soft and flexible.
Why robots need to soften up
The research responds to a shift in where robots operate. Most still depend on rigid mechanical parts, but they are increasingly expected to work alongside people in hospitals, care settings, homes and workplaces, where softer and more adaptable machines would be safer.
Living muscle offers a model because it handles movement, sensing and reaction to stimuli at once. “If we want people to interact safely with robots in places such as hospitals, we need to move away from completely rigid structures,” Abdi said.
He acknowledged that replicating several muscle functions in one artificial structure remains a major challenge, despite extensive research in soft robotics. His target for the fellowship is a prototype that shows what is possible and lays the groundwork for further research.
3D printed muscles for safer robots
Abdi’s strategy is to use additive manufacturing to design structures where geometry, not just material, defines performance. The gap he targets is that soft robots still lack muscles that can move, sense and harvest energy in one structure, and that the best piezoelectric materials are too stiff, brittle or lead-based for that role.
Other researchers are also turning to 3D printing to build muscle-like actuation into the material itself. At Harvard, Jennifer Lewis’s lab used rotational multimaterial 3D printing to produce hair-thin filaments that bend and contract like biological muscle. The filaments pair an active liquid crystal elastomer with a passive elastomer, so their shape change is programmed during printing.

At MIT, researchers developed a biofabrication technique for multi-directional artificial muscle tissue. It uses a 3D printed stamp to pattern grooves in a soft hydrogel that guide how muscle cells grow. The team points to muscle-based actuators as energy-efficient alternatives to rigid components in soft robotics.
Movement, sensing and energy harvesting in one printed structure remains a major challenge. Abdi’s fellowship aims to show it can begin to come together in a single prototype.
To stay up to date with the latest 3D printing news, don’t forget to subscribe to the 3D Printing Industry newsletter or follow us on LinkedIn.
Explore the full Future of 3D Printing and Executive Survey series from 3D Printing Industry, featuring perspectives from CEOs, engineers, and industry leaders on the industrialization of additive manufacturing, 3D printing industry trends 2026, qualification, supply chains, and additive manufacturing industry analysis.
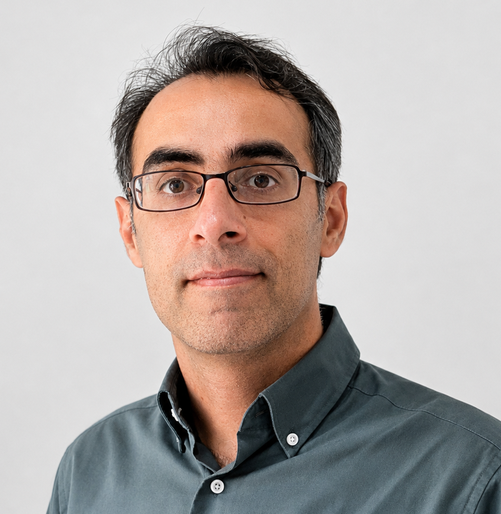
Featured image shows Dr Meisam Abdi. Photo via De Montfort University Leicester.
